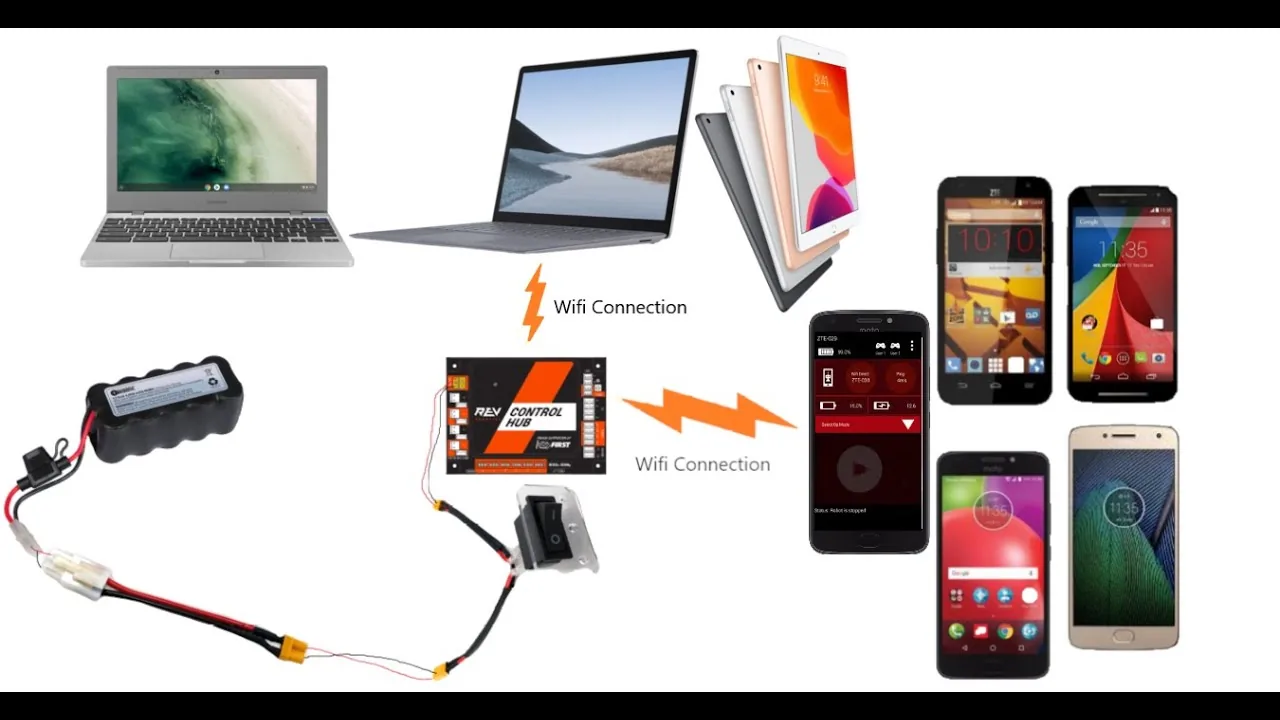
Video tutorials
A video series on programming and electrical setup for FTC, to get beginner teams’ robots moving. I made it to make easy the things I found hard when I started.
I work across embedded firmware, controls and mechanical design. Most recently I wrote implant firmware at Neuralink and vehicle lighting firmware at Tesla. Below is a selection of projects, starting with a ball-balancing Stewart platform.
Redesigned a ball balancing platform for a 200× heavier ball: a topology-optimized plate, stronger links and a ball-joint-free manipulator.
Designed the cam mechanism that drives three panels from one servo, and co-wrote the firmware that steers Borealis to its target apogee.
Led the firmware for a station that measures parts to 0.3 mm, including a custom 2-wire protocol to the VEX brain.
Led firmware for a 1st-gen neural stimulation implant: interrupt-driven, DMA-fed, high-throughput code coordinating waveforms and sampling for 3k+…
Brought up all ~20 exterior lights on the Tesla Semi and their current-sense ADCs, from the hardware layer through to app-layer integration, writing the C…
Built video streaming from smart glasses to a smartwatch over Ixana's Wi-R body-coupled silicon, using the body as an ultra-low-power data bus.
Streamed strain-gauge data from a hydraulic press over MQTT into PostgreSQL, with a live web dashboard for operators.
An autonomous back-up safety system for industrial garbage trucks: 10 LiDARs, 3 depth cameras, an IR camera, IMU and GPS across 6 microcontrollers.
Designed and built an autonomous surface robot that collects floating trash, meant to work in swarms.
Modelled twenty-plus parts from orthographic drawings and assembled them into a working six-cylinder linkage.
Designed and FEA-tested an ultra-low-profile clamping shaft hub, now sold commercially by Studica.
Built a MuJoCo–ROS 2 bridge for the Franka Panda, with force injection to benchmark contact localization.
Took a 1-D ball balancer from linkage design to working firmware in two weeks.
Derived the equations of motion for a human transporter by hand and checked them in Simulink against SimulationX.
Wrote the STM32 firmware: interrupt-driven endstops, homing, UART positioning and an ADC-characterized pot.
Wrote filtering, voxel downsampling and a fast furthest-pair search for millions of points.
All software, solo. Control Award at the Asia Pacific Open Championship.
Organized the event and built a ring-launching robot in 48 hours with five people.
Designed a tracked drive concept for rough terrain, shown here as a CAD render.
Sweeps an area and sorts bird eggs by whether they are an invasive or protected species.
Built in under 8 hours from a Tetrix kit to pick up oddly shaped bones and sort them.
Hover one to see where it was used.
Robotics, beyond my own builds.
A video series on programming and electrical setup for FTC, to get beginner teams’ robots moving. I made it to make easy the things I found hard when I started.
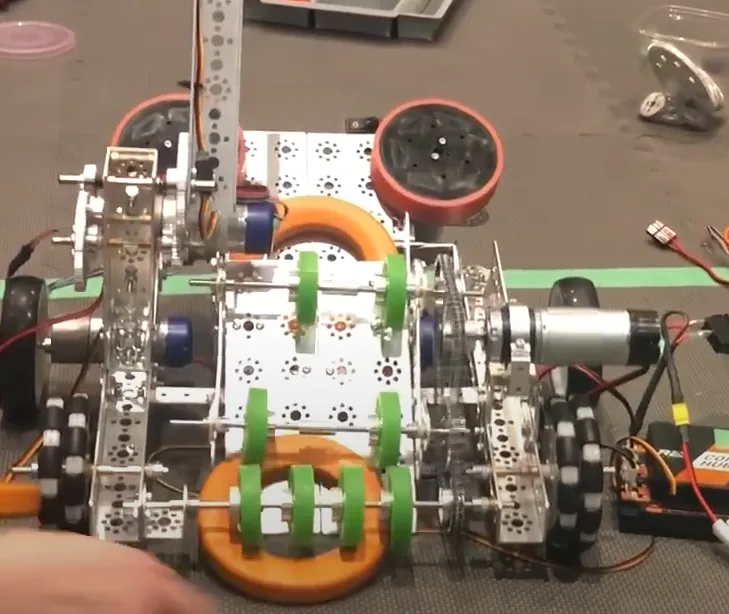
I personally mentor other FTC teams, most closely 18846 and 17003, with everything from mechanical design to programming reliability.
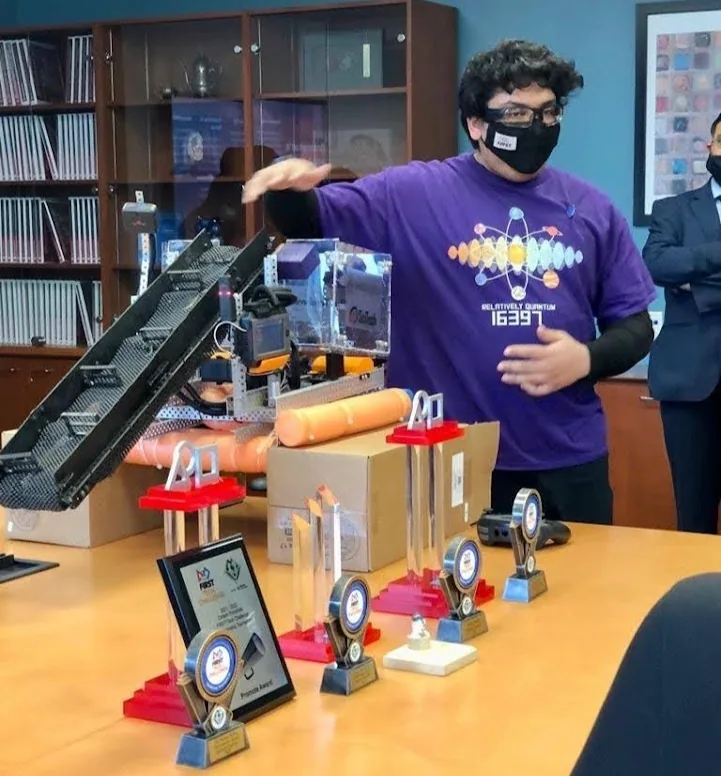
Robotics demos for companies and schools beyond the robotics community, including Sheridan College, the City of Brampton, BGC Peel, OpenText and middle schools.
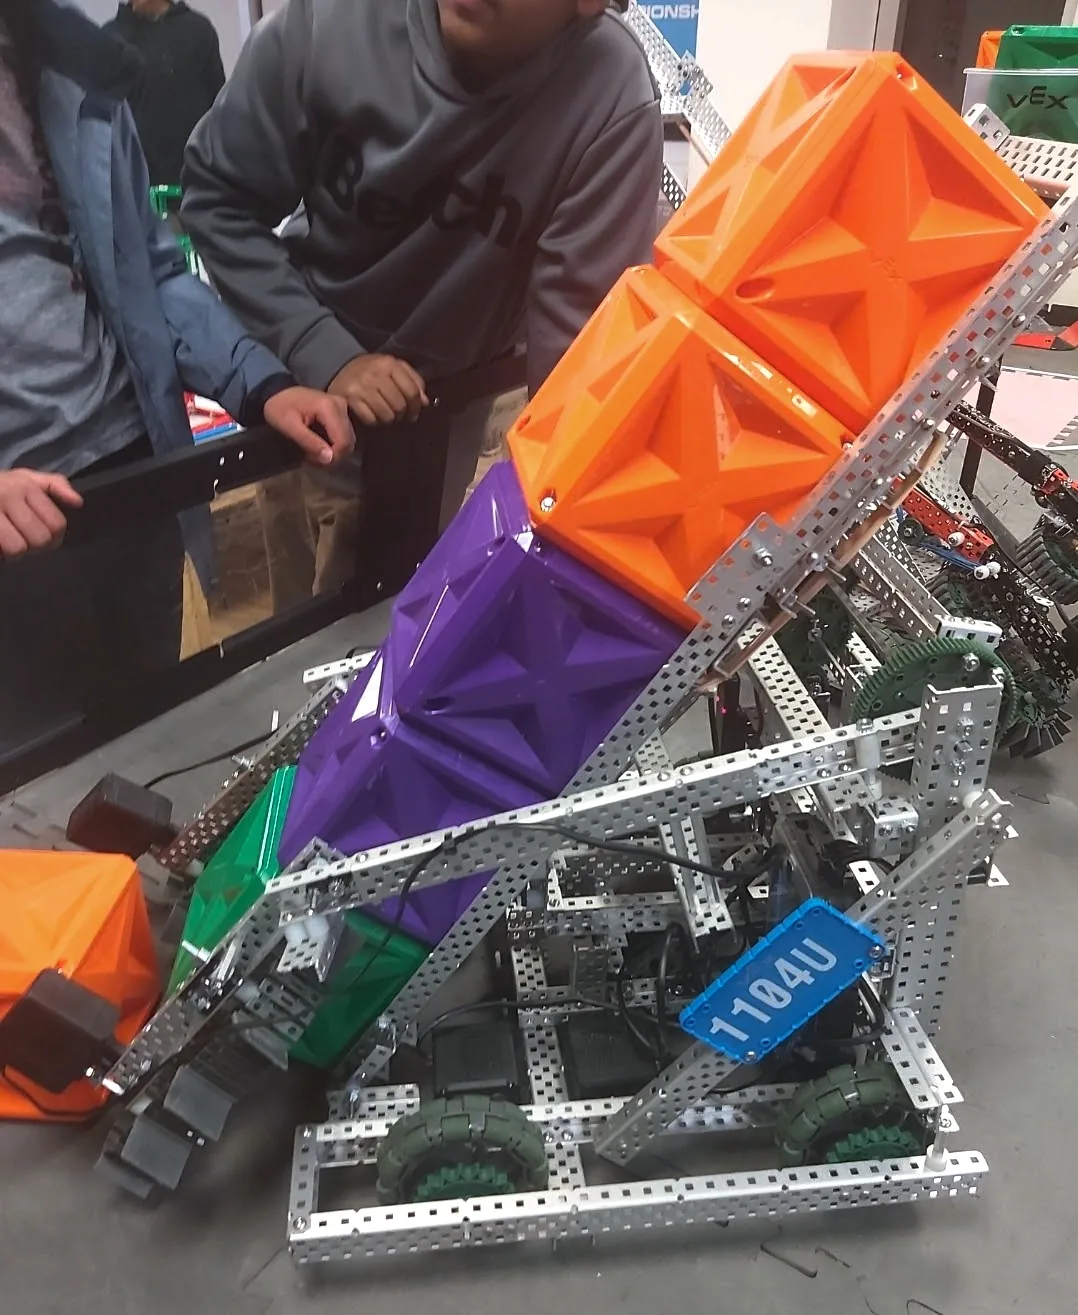
With FIRST Canada we gave 38 robotics kits to schools without a robotics club, then taught them over two summers, from building to programming robots.
I beta tested and then publicly demoed FTC Sim, a virtual robotics simulator, and was then hired by FIRST Canada to teach classes on it for two years.
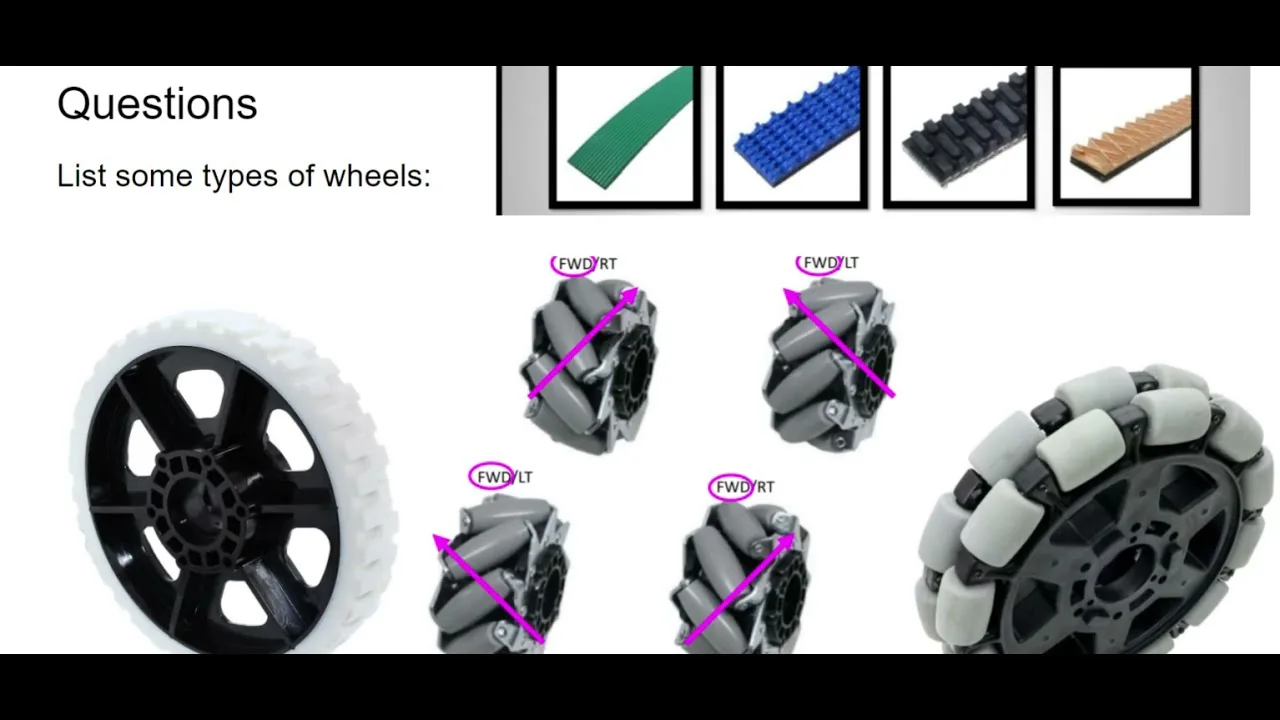
As captain of my high school’s FRC team, I created and organized the lessons for newcomers, and taught the mechanical design lessons.
