Projects / LiDAR Point Clouds
LiDAR Point Clouds
Wrote filtering, voxel downsampling and a fast furthest-pair search for millions of points.
Projects / LiDAR Point Clouds
Wrote filtering, voxel downsampling and a fast furthest-pair search for millions of points.
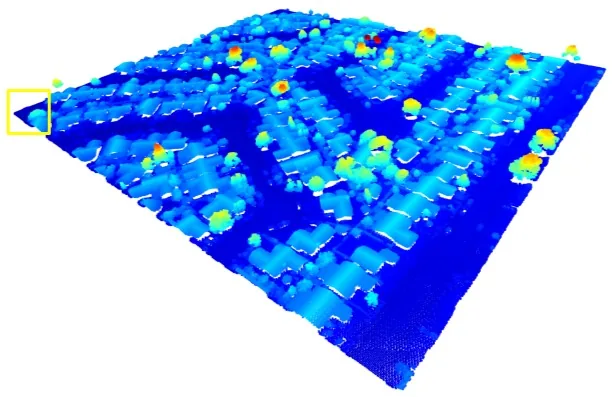
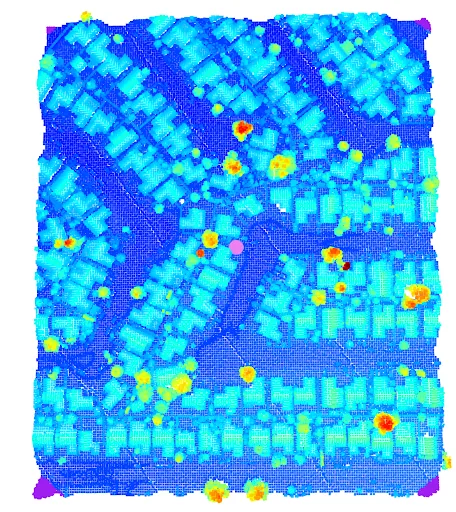
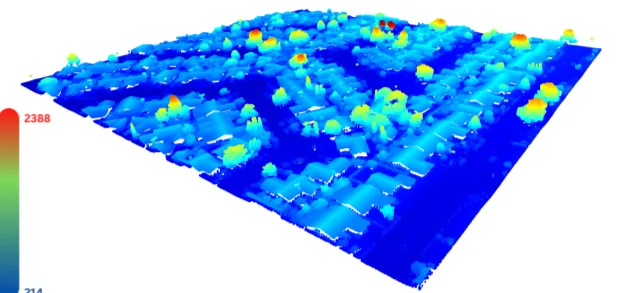
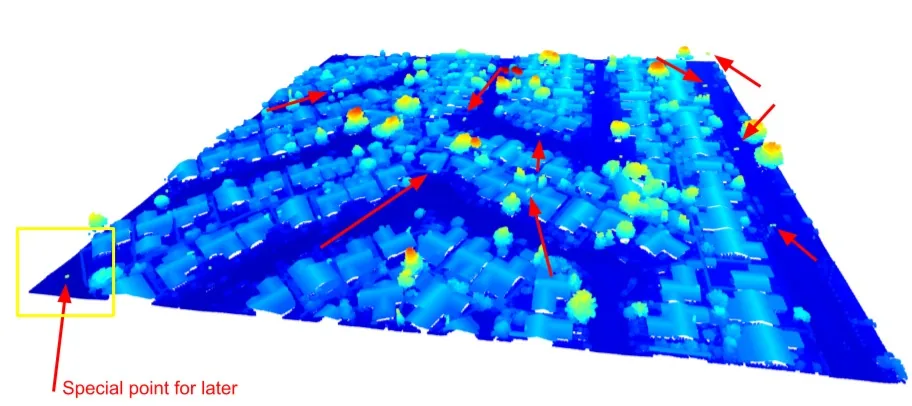
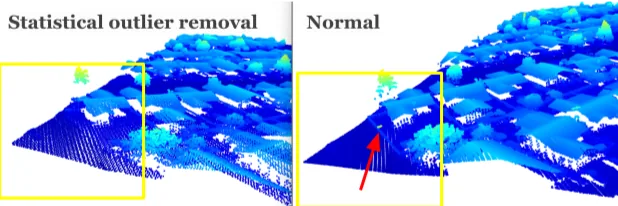
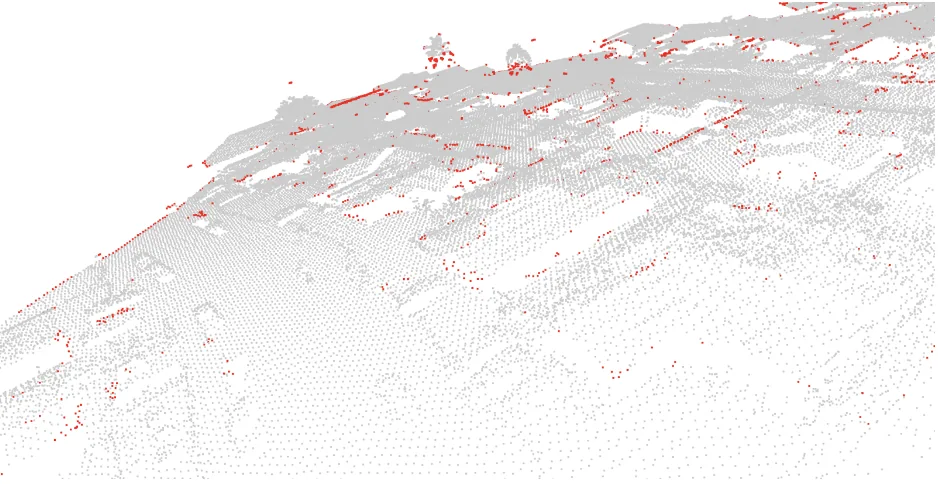
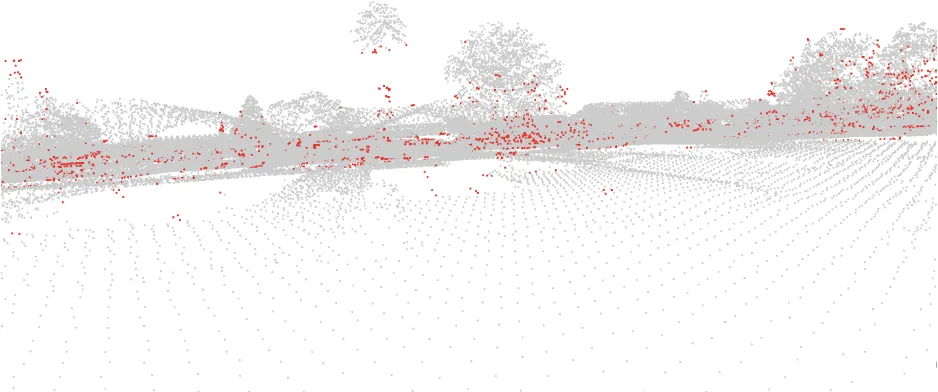
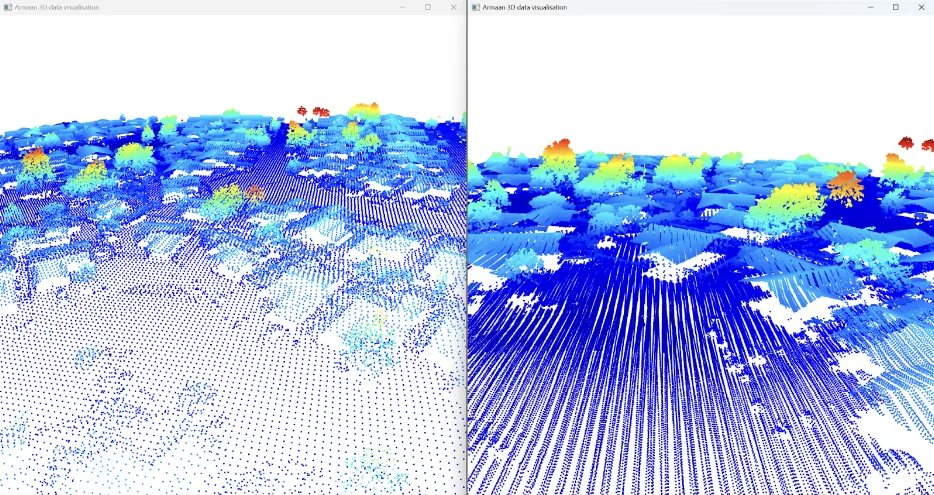
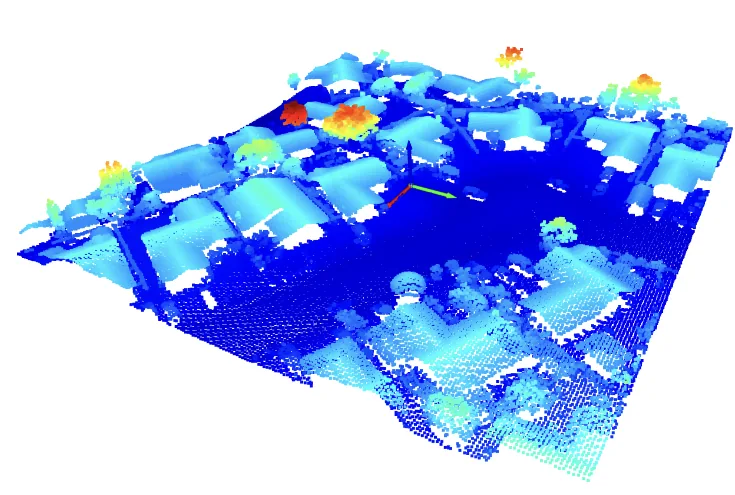
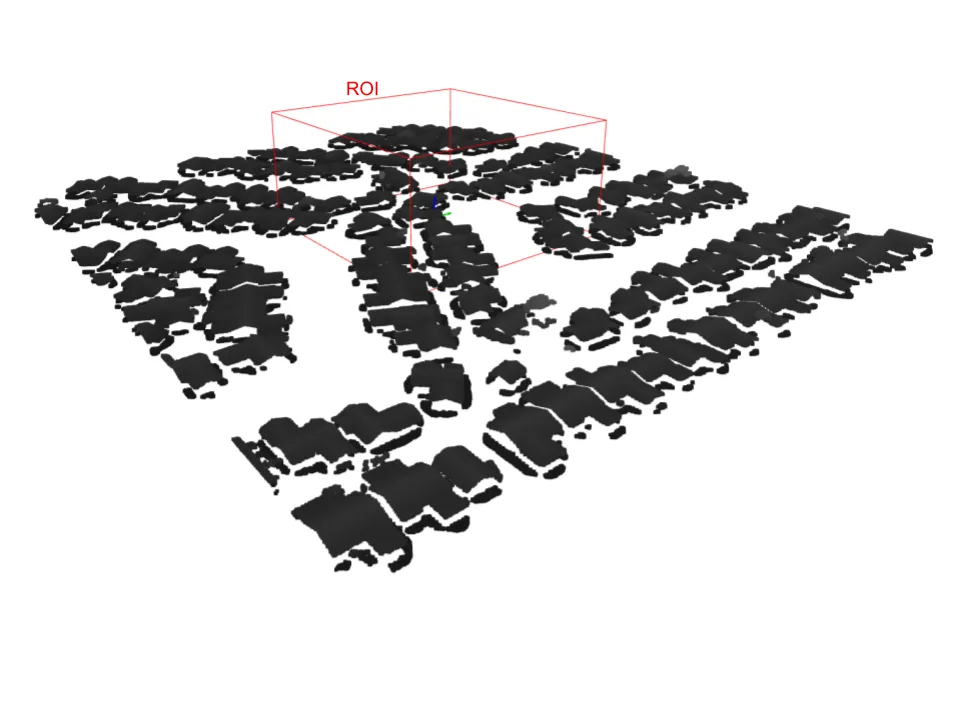
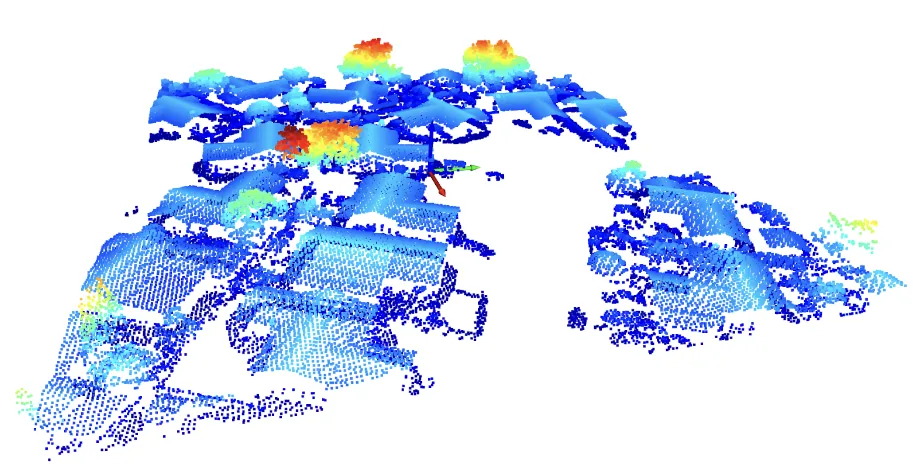
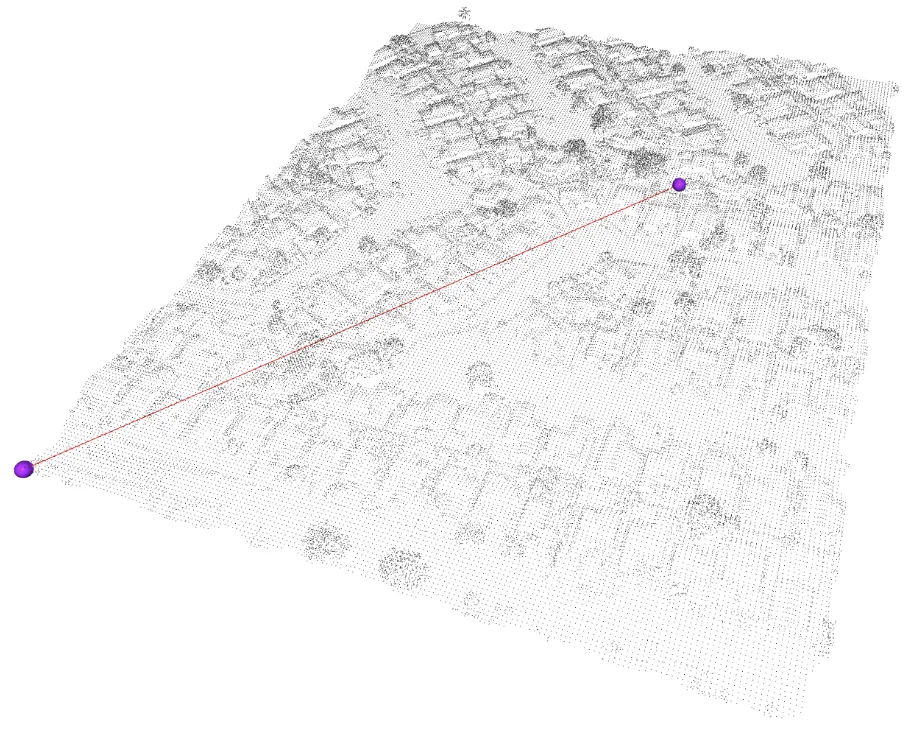
Processing a large urban LiDAR scan with laspy, Open3D and NumPy: voxel downsampling, a nearest-neighbour outlier filter for dust and artifacts, and a custom furthest-pair search fast enough for 1M+ points.
I wrote a pipeline to manipulate, clean and analyze a massive LiDAR point cloud: removing anomalies, extracting buildings, and finding the two furthest points in a set of millions, a good excuse to try some fun algorithms.
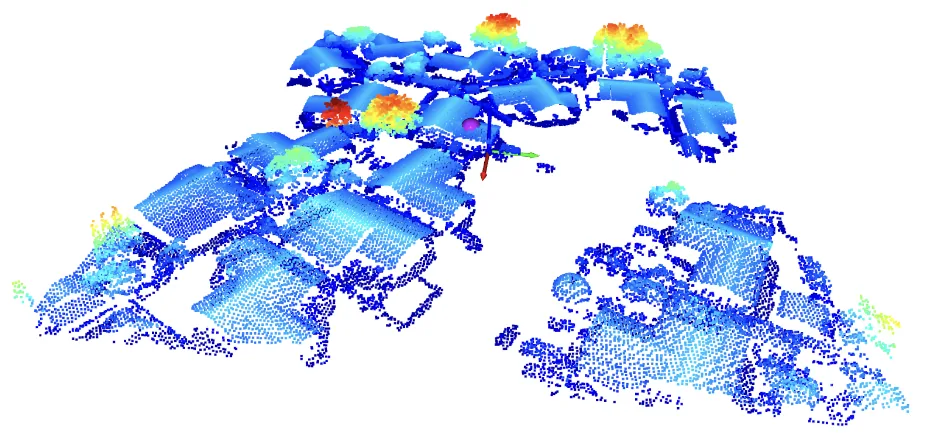
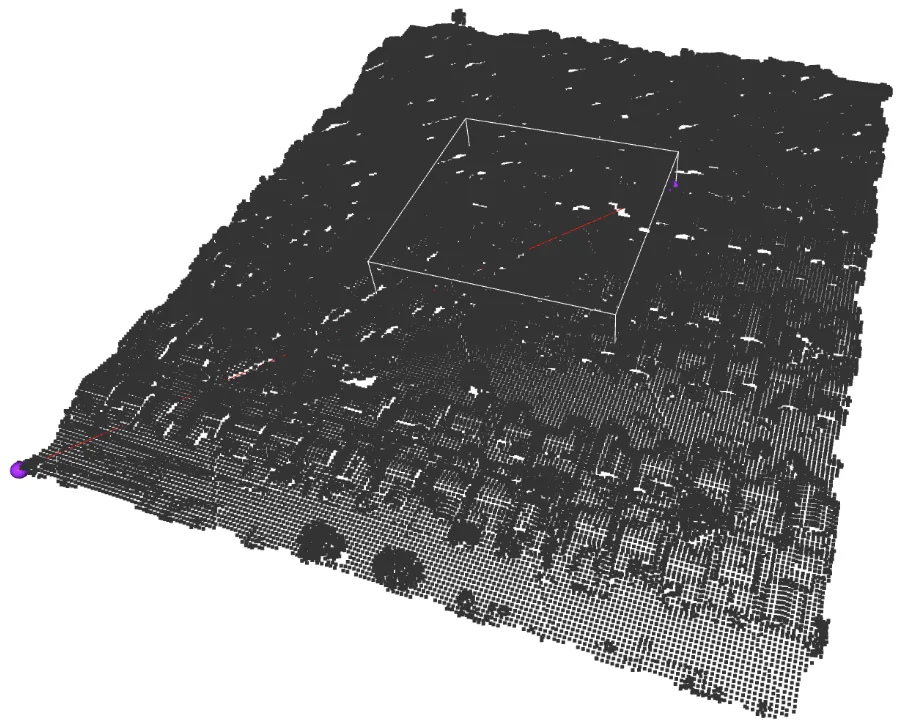
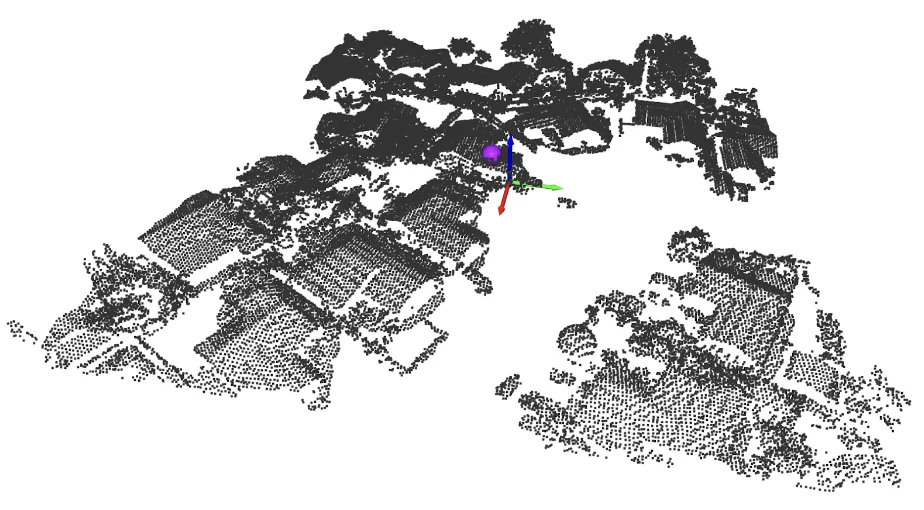
See it on the interactive siteCode and write-up ↗Code & details (GitHub) ↗3D point cloud online ↗