Projects / Two-Axis Gantry
Two-Axis Gantry
Wrote the STM32 firmware: interrupt-driven endstops, homing, UART positioning and an ADC-characterized pot.
Projects / Two-Axis Gantry
Wrote the STM32 firmware: interrupt-driven endstops, homing, UART positioning and an ADC-characterized pot.
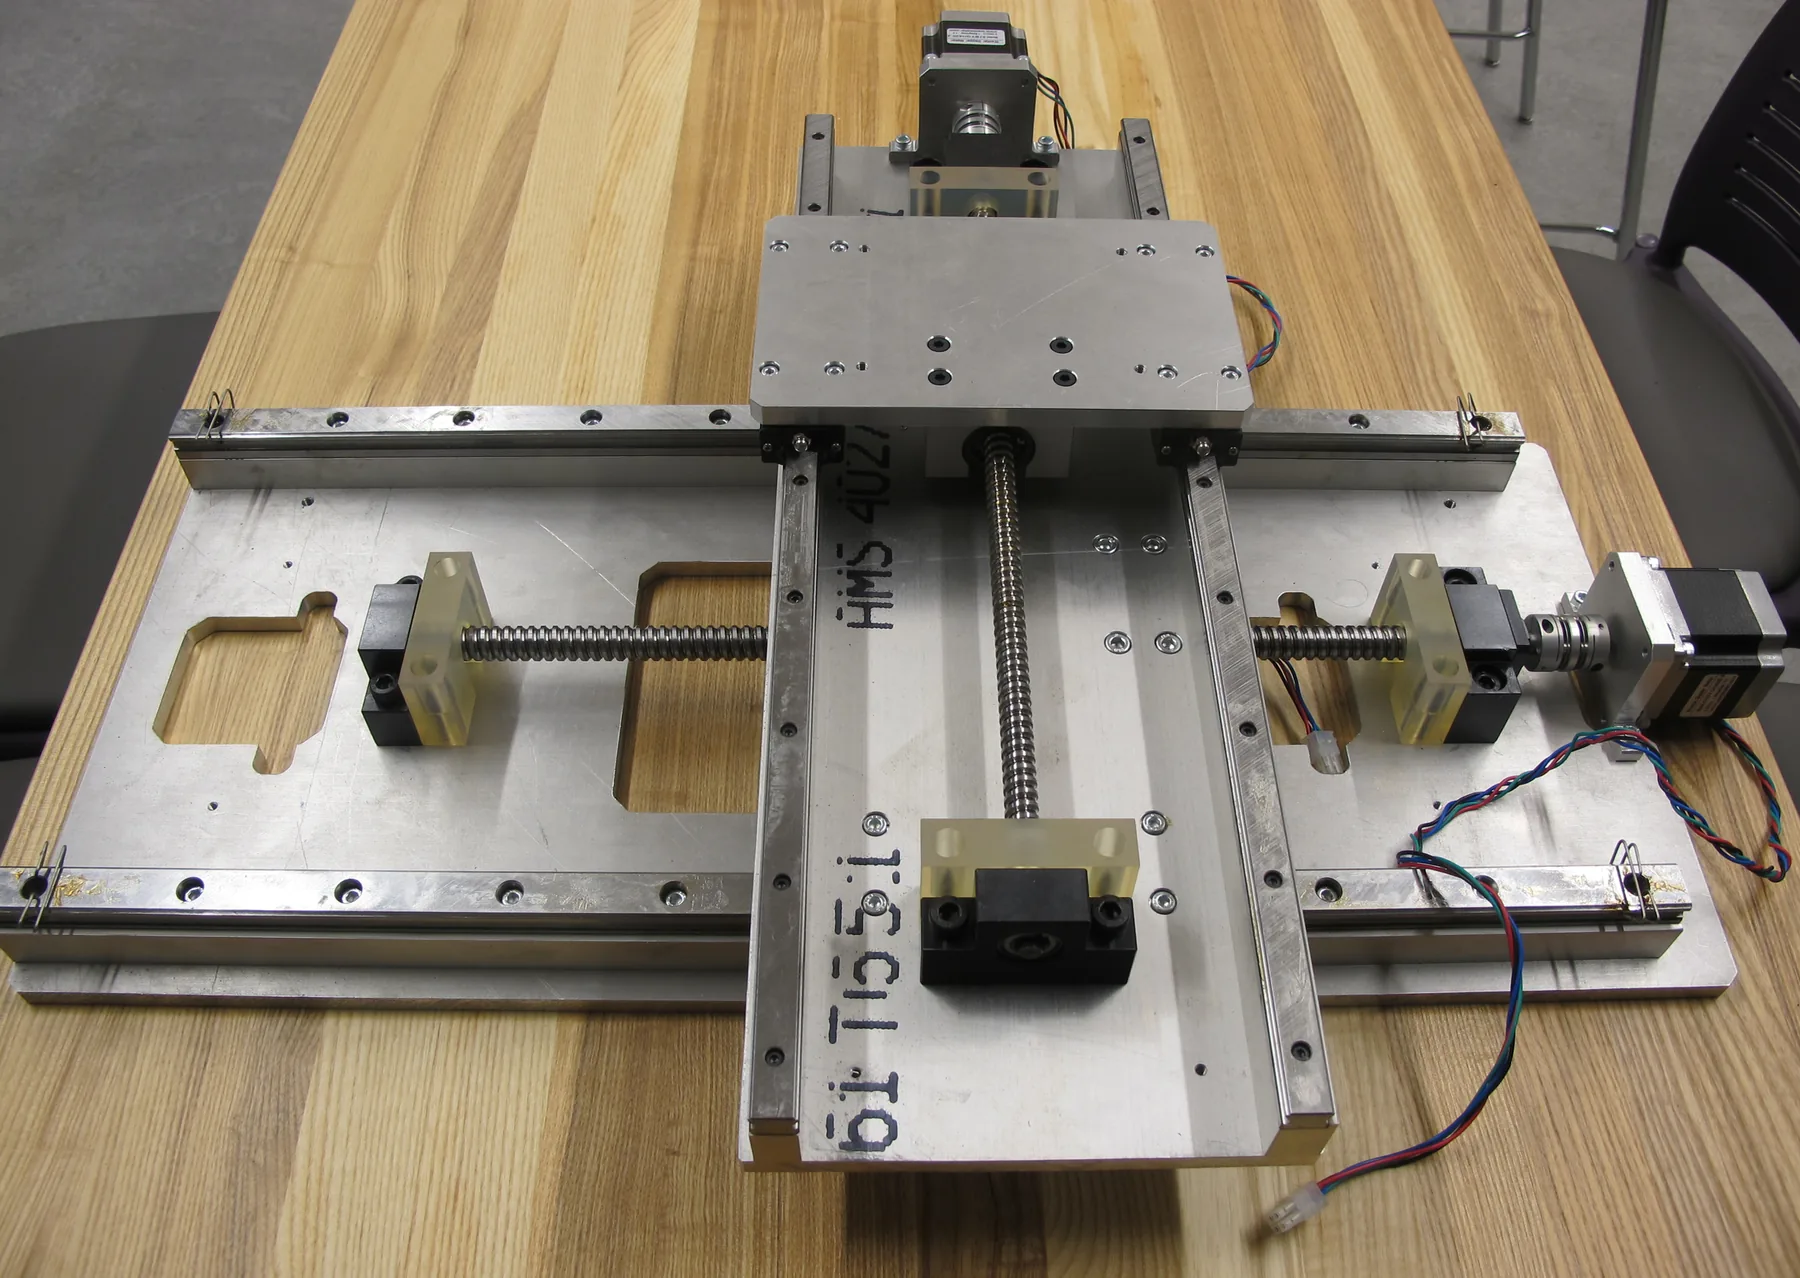
An STM32 drives two stepper axes. Interrupts on the endstops stop motion into a limit, a homing routine zeros the machine, UART sets position from a PC, and a characterized ADC lets a potentiometer position each axis precisely.
I wrote STM32 firmware to control a two-axis machine over UART and a potentiometer, with safety stops and homing. Interrupts catch the endstops so the machine never drives past a limit, and I characterized the ADC so the potentiometer sets each axis precisely. The final demo showed safe stops at the limits and a race to position the machine over a target as fast and precisely as possible.